Robotics Development · Peachtree City, Georgia
Custom robotics, built around your mission.
Roberson Robotics develops rugged electric ground platforms for security, hazardous inspection, payload transport, and advanced UGV research. We partner with integrators and mission owners to turn operational requirements into working robotic systems.
Mechanical DesignElectric PropulsionEmbedded ControlSensor IntegrationRapid Fabrication
The physical-integration partner
Custom robotics development in Peachtree City, Georgia.
Based in Peachtree City, Georgia, Roberson Robotics develops custom robots, autonomous ground vehicles, and working robotic prototypes for demanding applications.
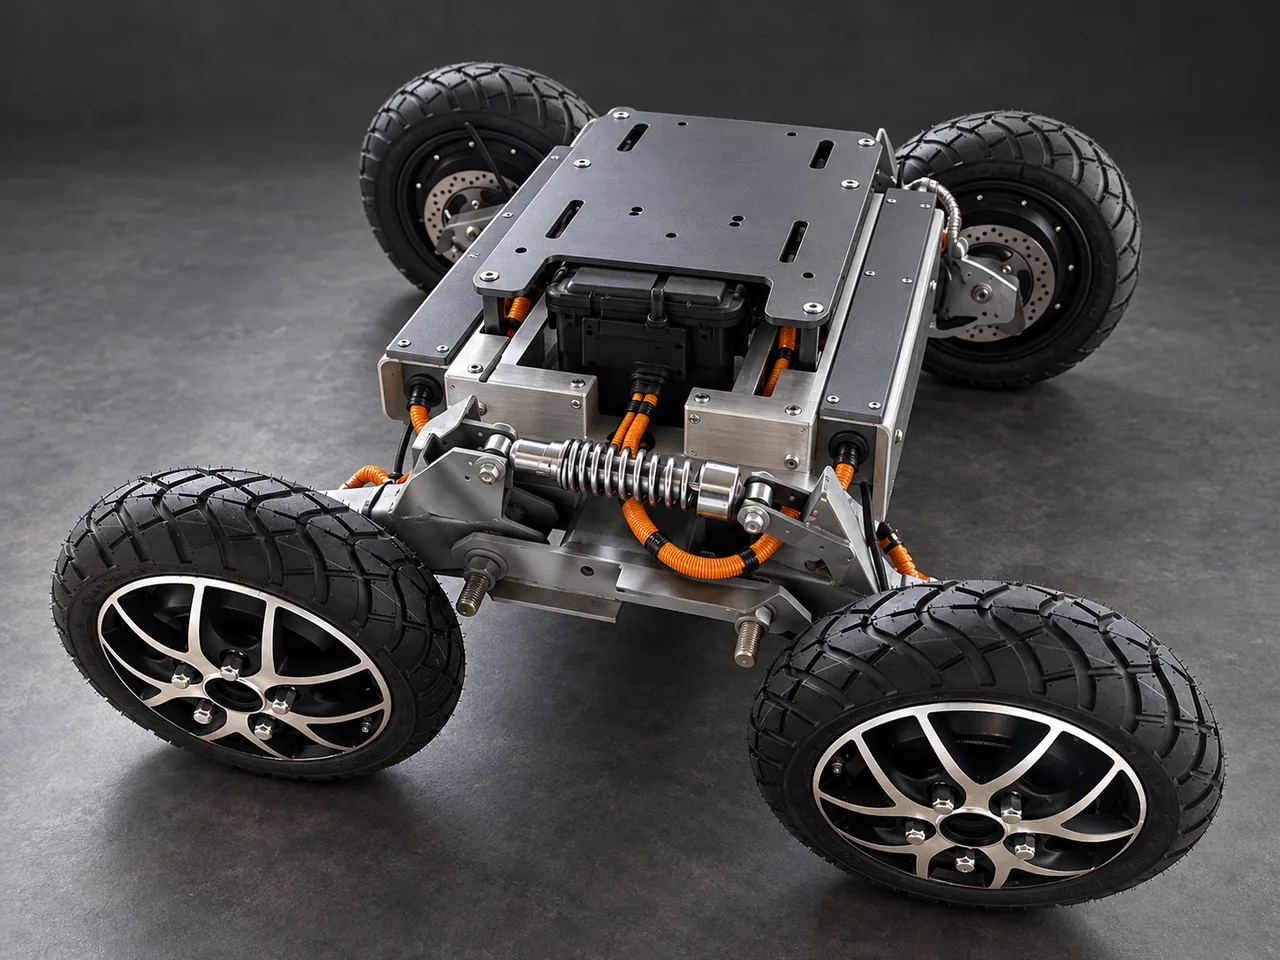
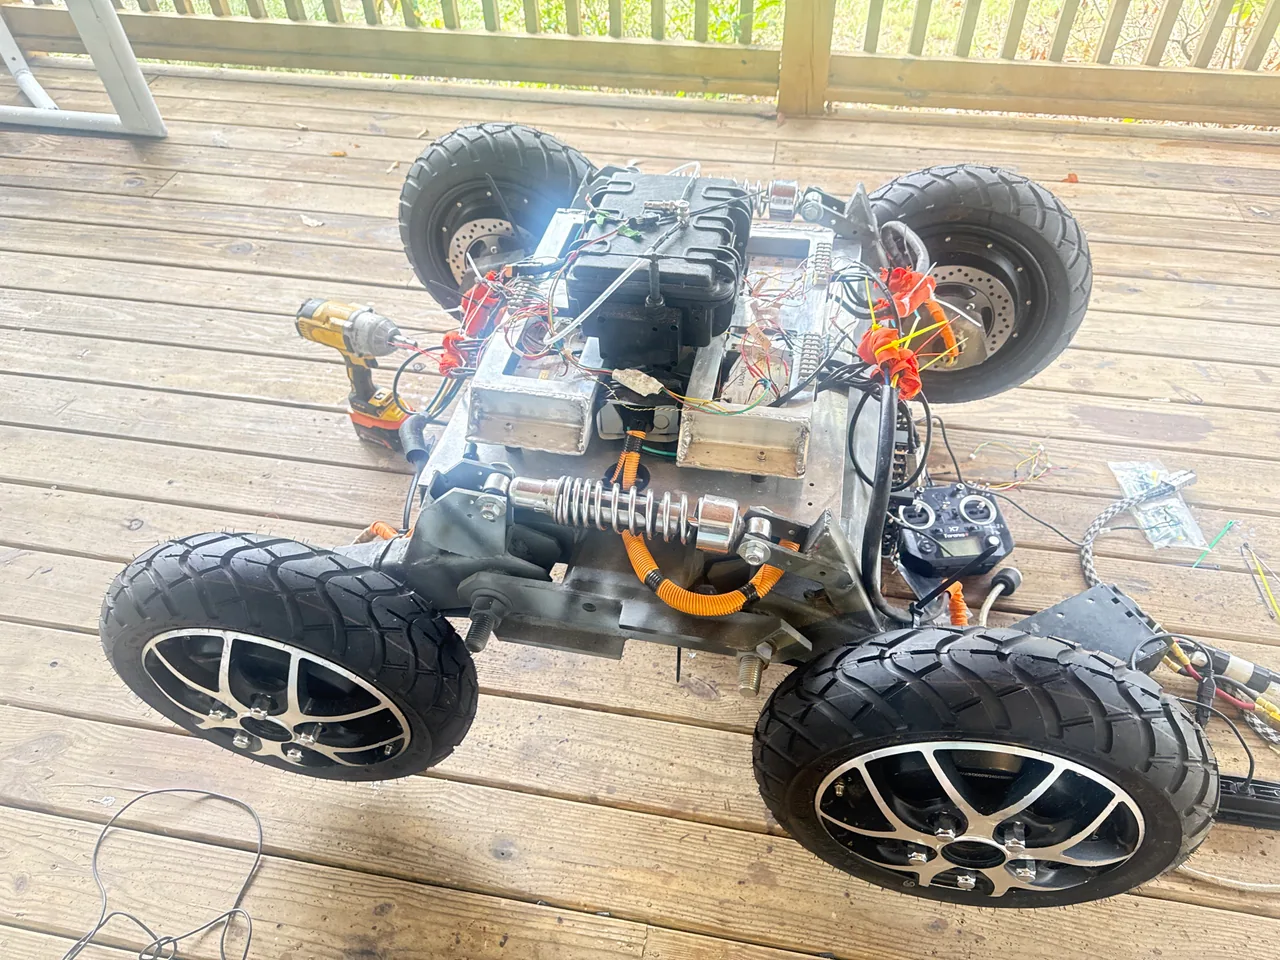
From the X4 flagship to wheeled and biped prototypes, our work connects mechanical design, electric propulsion, embedded control, and autonomy into a practical robotic system.
We own the difficult physical layer: structure, propulsion, suspension, real-time control, power, vehicle dynamics, payload integration, and fault handling.
Priority applications
Four missions. One adaptable mobility foundation.
Perimeter security
Mobile observation, remote presence, route patrol, sensor deployment, and rapid alarm investigation.
Hazardous inspection
Remote inspection and sensor placement where personnel exposure should be minimized.
Payload transport
Move tools, supplies, communications, and mission equipment across terrain unsuitable for smaller robots.
UGV research & integration
A configurable mobility and power base for autonomy, sensing, communications, and academic R&D.
Developed prototypes
Different architectures. The same hands-on engineering.
Two additional Roberson Robotics prototypes exploring distinct approaches to robotic mobility.
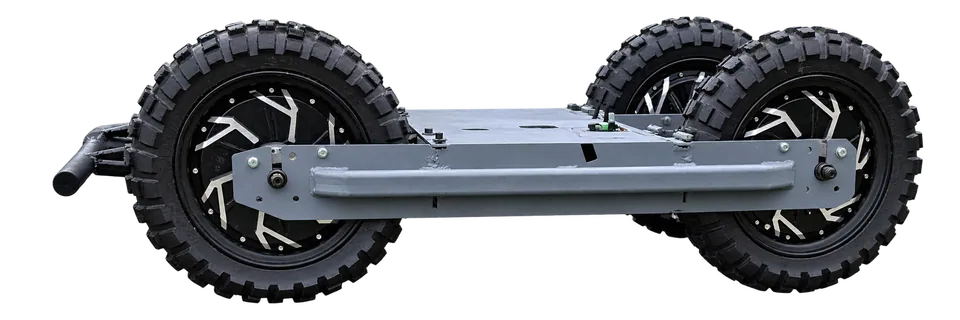
Four-wheel architecture
Low-profile wheeled prototype
A developed chassis prototype with a low frame and four-wheel mobility layout.
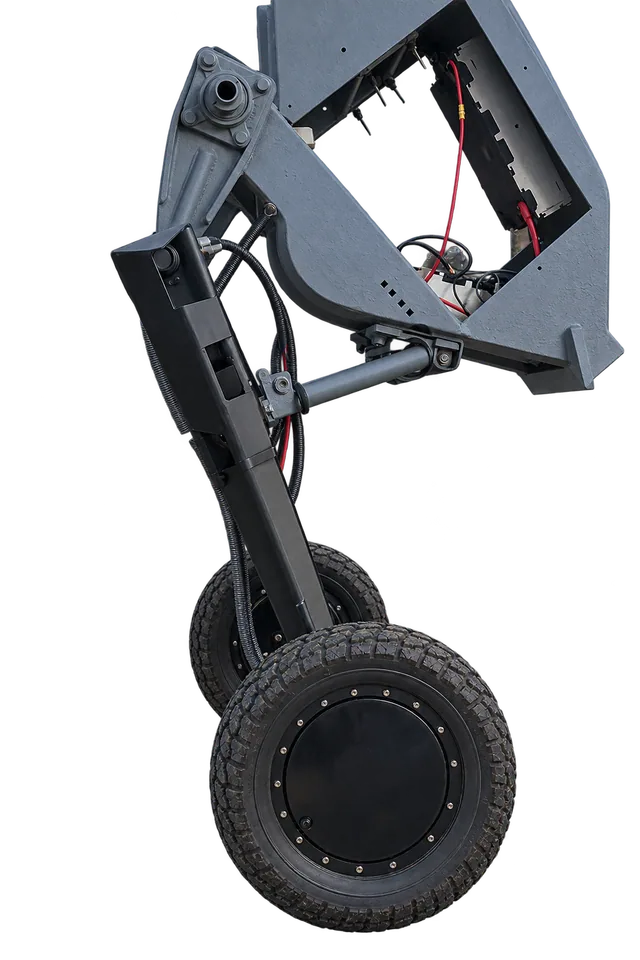
Wheeled biped architecture
Wheeled biped prototype
A developed prototype combining articulated leg structures with wheeled ground contact.
Engineering ownership
Designed as a system from the terrain up.
Electric propulsion
High-torque, independently managed drive channels with closed-loop command and health monitoring.
Mechanical systems
Rugged structures, independent suspension, fabrication, packaging, and serviceability.
Real-time control
Deterministic motion, link supervision, calibration gating, and motor-disable behavior.
Vehicle dynamics
Integration underway: closed-loop yaw control, traction logic, stability supervision, and rollover-risk mitigation.
Multi-modal perception
Lidar, depth-camera, and mmWave technologies support complementary perception and navigation capabilities.
Autonomy stack
A developed autonomy stack combines perception, navigation, and mission intelligence above a dedicated vehicle-control and safety layer.
Ways to engage
Start with a defined, low-risk technical objective.
Platform integration
Adapt an existing mobility architecture around your payload, sensors, communications, compute, and mission requirements.
Joint prototype development
Develop and demonstrate a mission-specific robotic prototype with defined milestones, test criteria, and deliverables.
Mobility & control subsystems
Provide or co-develop drivetrain, suspension, real-time control, power, telemetry, and vehicle-dynamics subsystems for a prime-led system.
Preferred entry point: a paid feasibility and prototype-definition engagement, followed by a milestone-based prototype program.
Review custom robot development and integration programs →Development-stage transparency
Functional platform development is underway.
Roberson Robotics is an early-stage, founder-led hardware company—not a mass-production OEM. Current work includes functional mobility and control architecture, with sensor, compute, stability, and mission-payload integration progressing by configuration.
Performance targets remain subject to engineering validation. Program discussions begin with requirements, evidence, risks, and a practical test plan.
Planning a robotics project
Custom robot development: common questions.
What does Roberson Robotics develop?
We develop custom ground robots and working robotic prototypes, connecting mechanical design, electric propulsion, embedded control, sensing, and mission-payload integration. The X4 modular robot platform is the flagship architecture; wheeled and wheeled-biped prototypes demonstrate additional mobility development.
Where is Roberson Robotics based?
Roberson Robotics is based in Peachtree City, Georgia. Program discussions begin with your application, operating environment, payload, and development objectives. Learn about the company and founder or discuss a robotics project.
Can a robot be configured for a specific application?
Yes. We develop around the required task and attachment interfaces, including mechanical mounting, power, communications, thermal limits, stability, and operator control. Inspection, remote observation, transport, and research are potential configurations, not claims of certified or deployment-ready systems.
Are the X4 speed and range figures guaranteed for every configuration?
No. The stated 45 mph top speed and 80-mile range are separate specifications, not a claim of 80 miles at 45 mph. Terrain, payload, speed, available energy, and duty cycle affect performance. Review the platform specification and maturity matrix for configuration boundaries.
How are proprietary designs and technical details handled?
Public information describes system capabilities and integration boundaries. Component selections, schematics, control implementation, and detailed qualification evidence are reserved for appropriate technical review under NDA. Start with non-sensitive requirements through the program inquiry form.
Start a technical conversation
Have a payload, sensor suite, or operational problem?
Define the mission, terrain, payload, timeline, and success criteria. We’ll identify the fastest credible path to a working prototype.